Research Projects
TeleRIPE: Constraint-Aware Haptic Guidance for Safe Fruit Harvesting
About the project
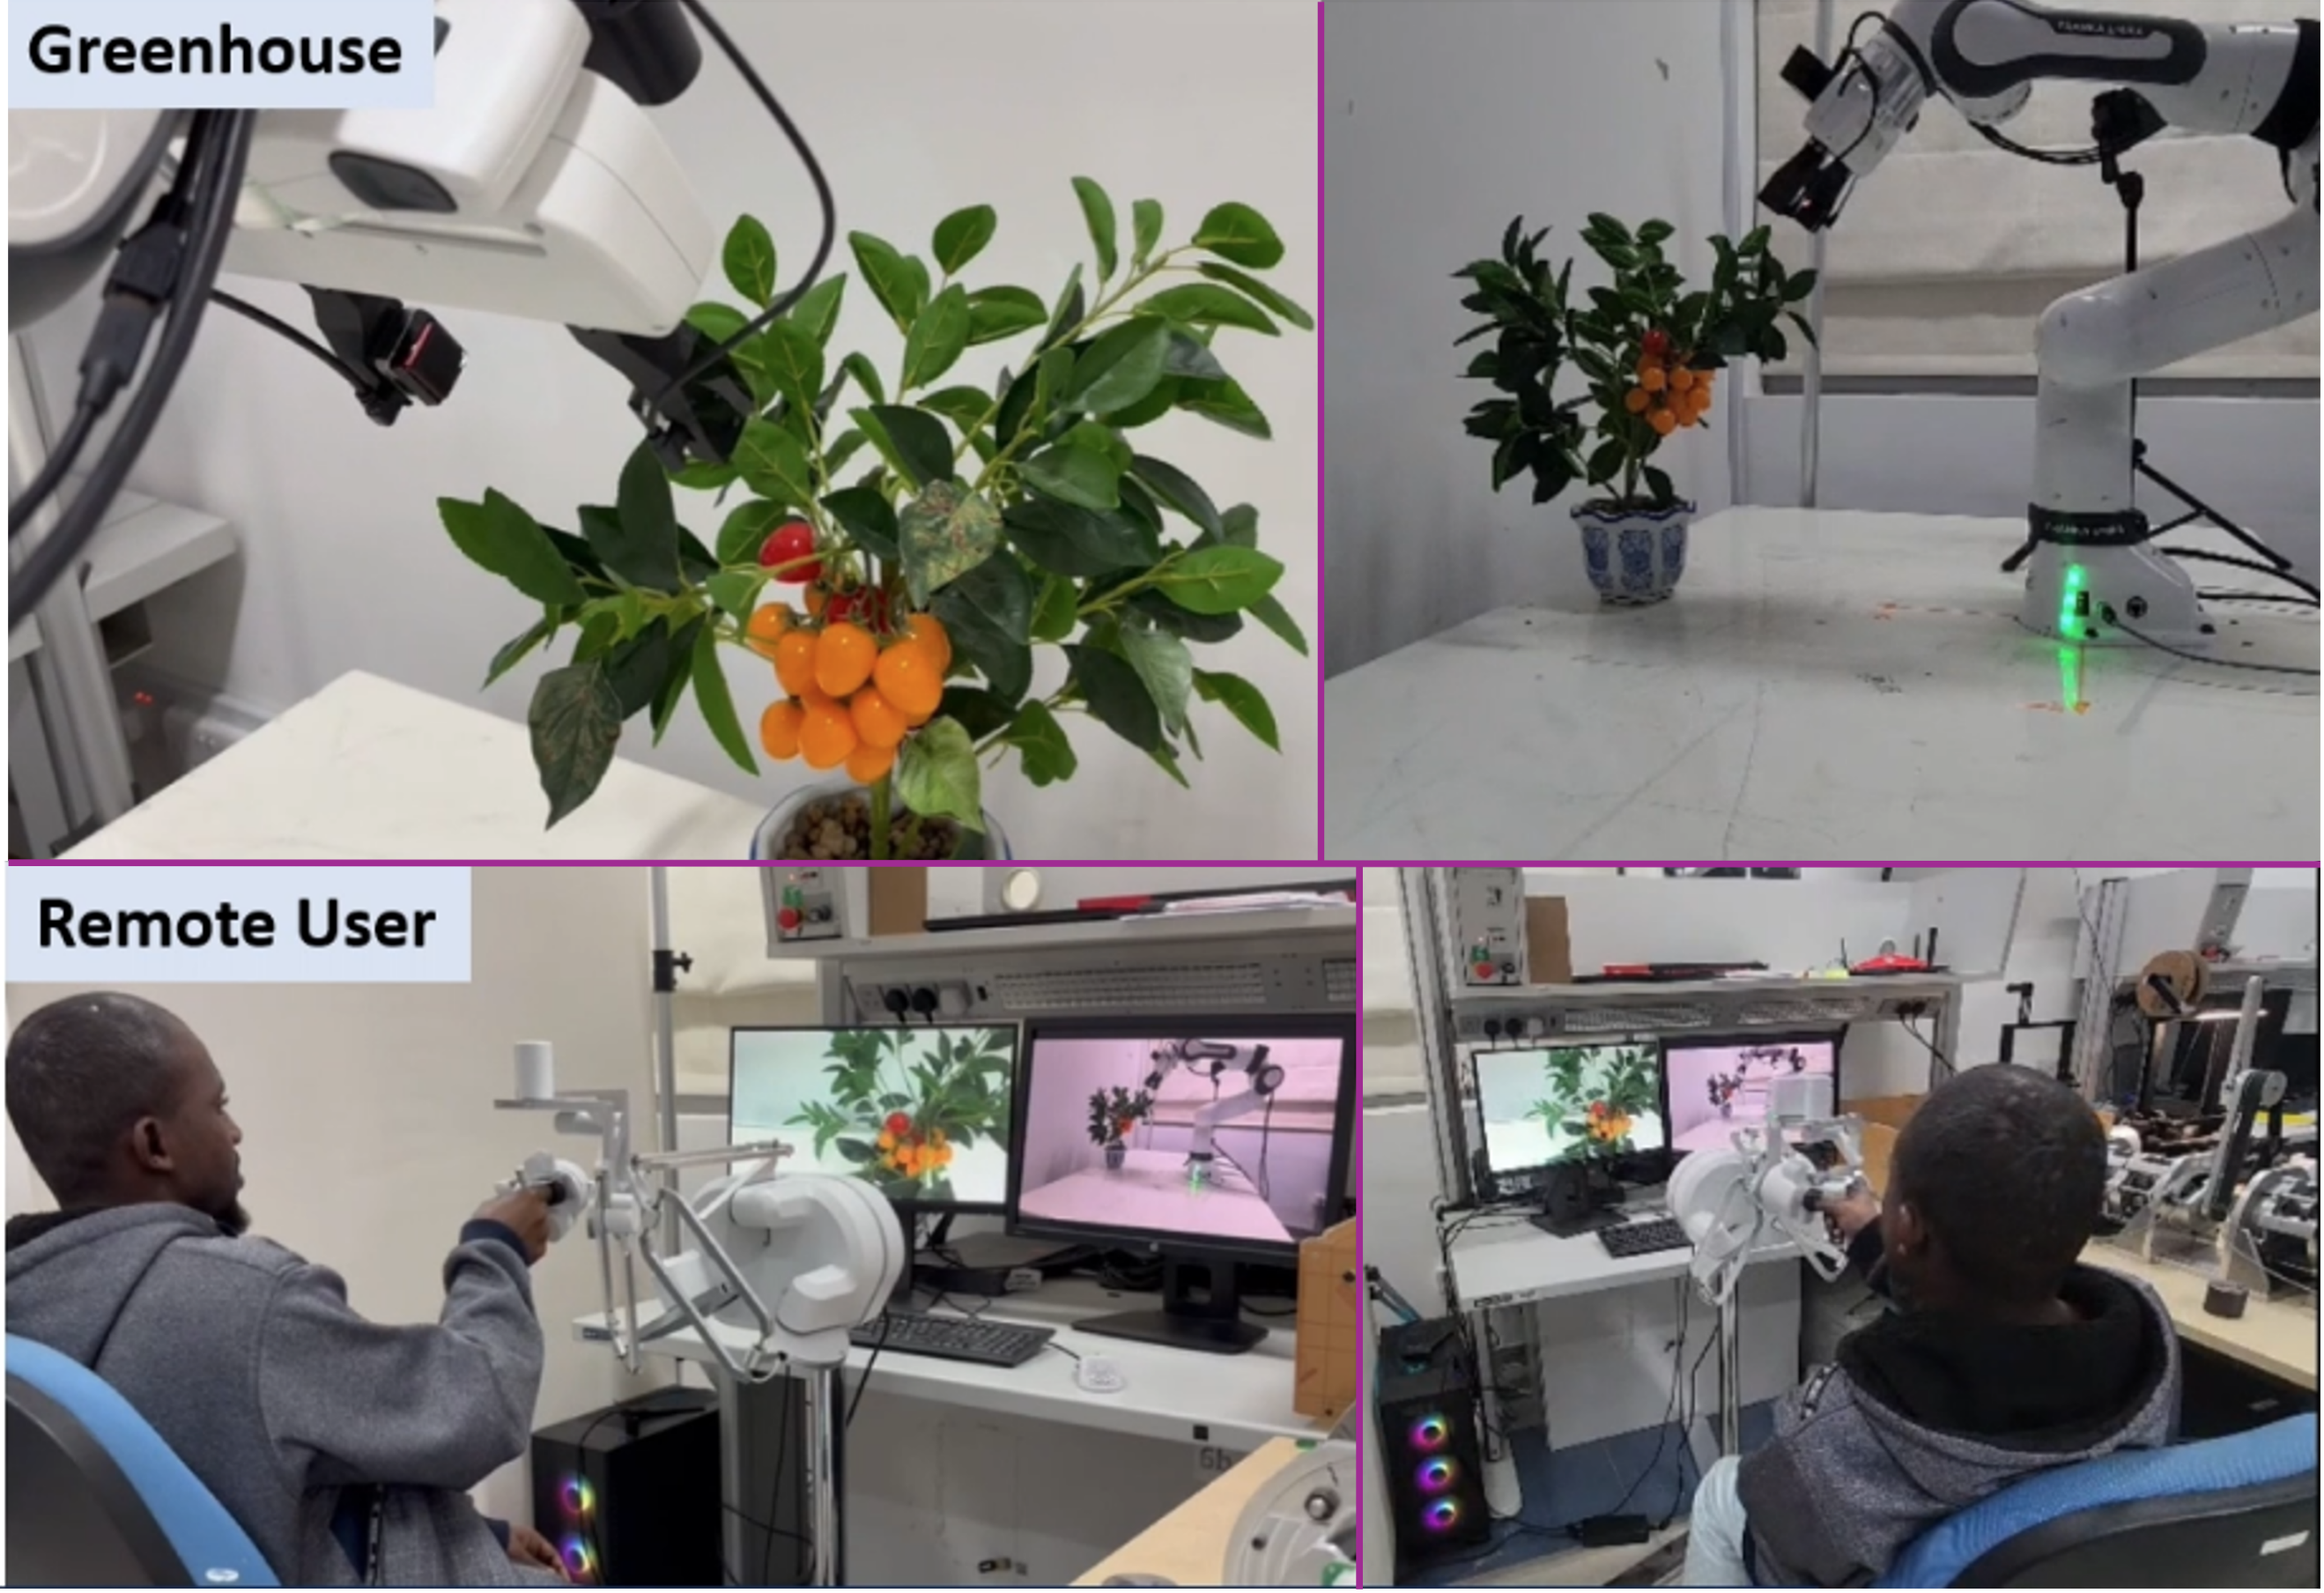
Fruit harvesting requires complex manipulation where fully autonomous robot learning risk violating safety constraints such as joint limits and self-collision. While human guidance can help, existing methods rarely provide clear haptic feedback that prevents issuing unsafe commands. We present a bilateral teleoperation framework that delivers transparent, constraint-aware haptic cues in human-guided robot learning: as the robot nears a safety boundary, a push–pull force is applied to the operator’s hand to discourage unsafe motions. This enables safer and more effective human demonstrations, helping robots learn complex harvesting behaviors while maintaining safety limits.