Research Projects
Teleoperated fruit firmness assessment and harvesting with haptic feedback for precision agriculture
About the project
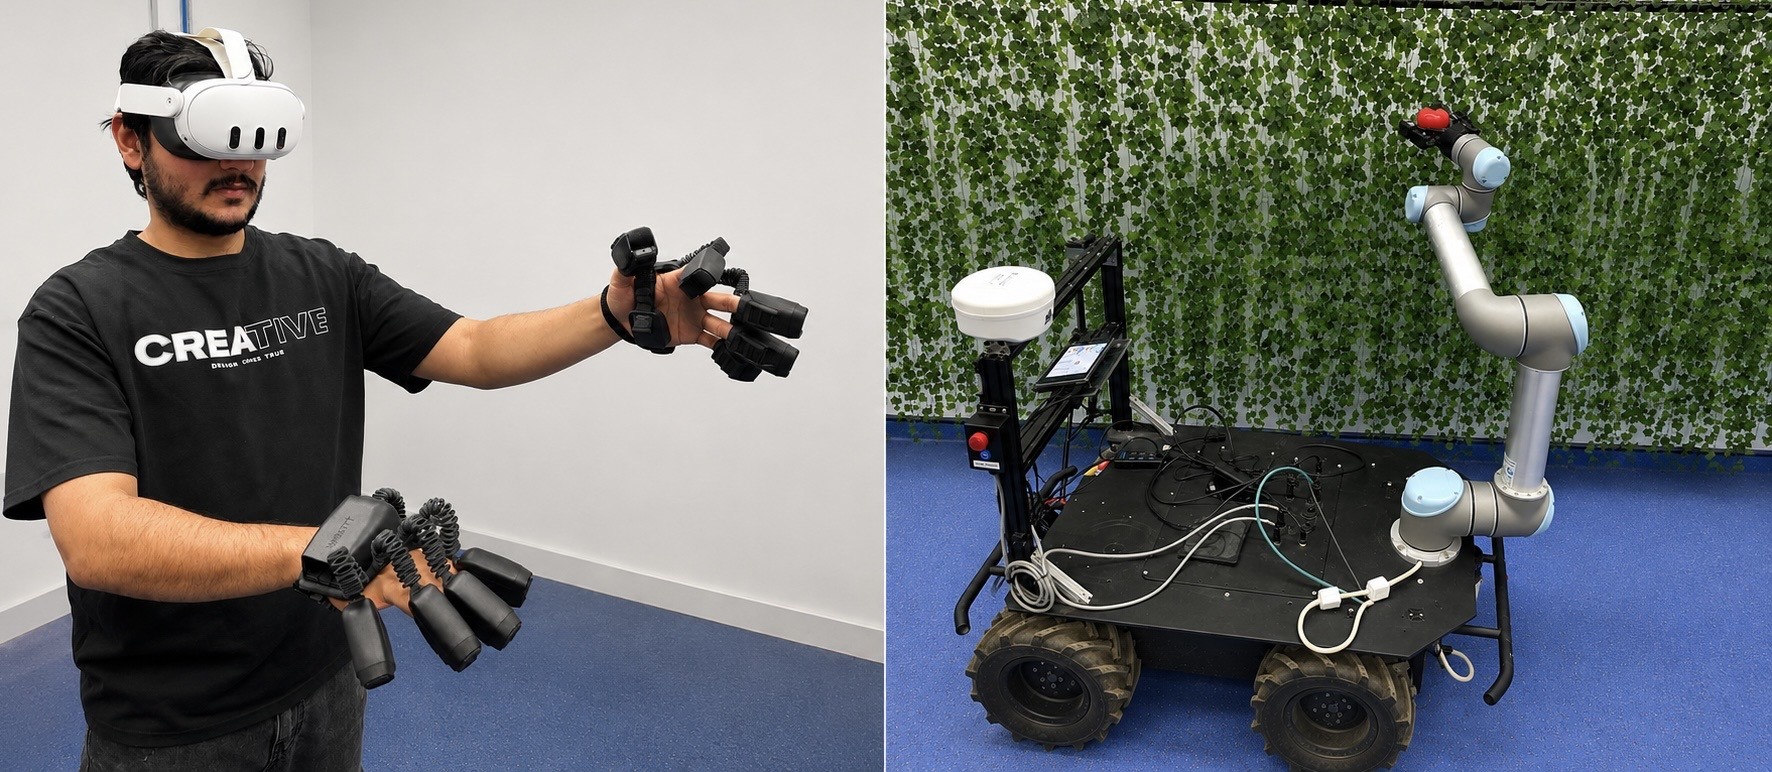
TeleRIPE is a VR-based robotic teleoperation system for remote fruit assessment and harvesting. It tracks the operator’s hand movements through a VR headset and WEART haptic gloves, enabling the robotic manipulator and gripper to follow the same movements in real time while providing tactile sensations for natural fruit interaction and ripeness assessment.