Research Projects
PackRIPE : A Human-Inspired Tactile–Vision Robotic Framework for Postharvest Fruit Handling and Integrated Quality Assessment
About the project
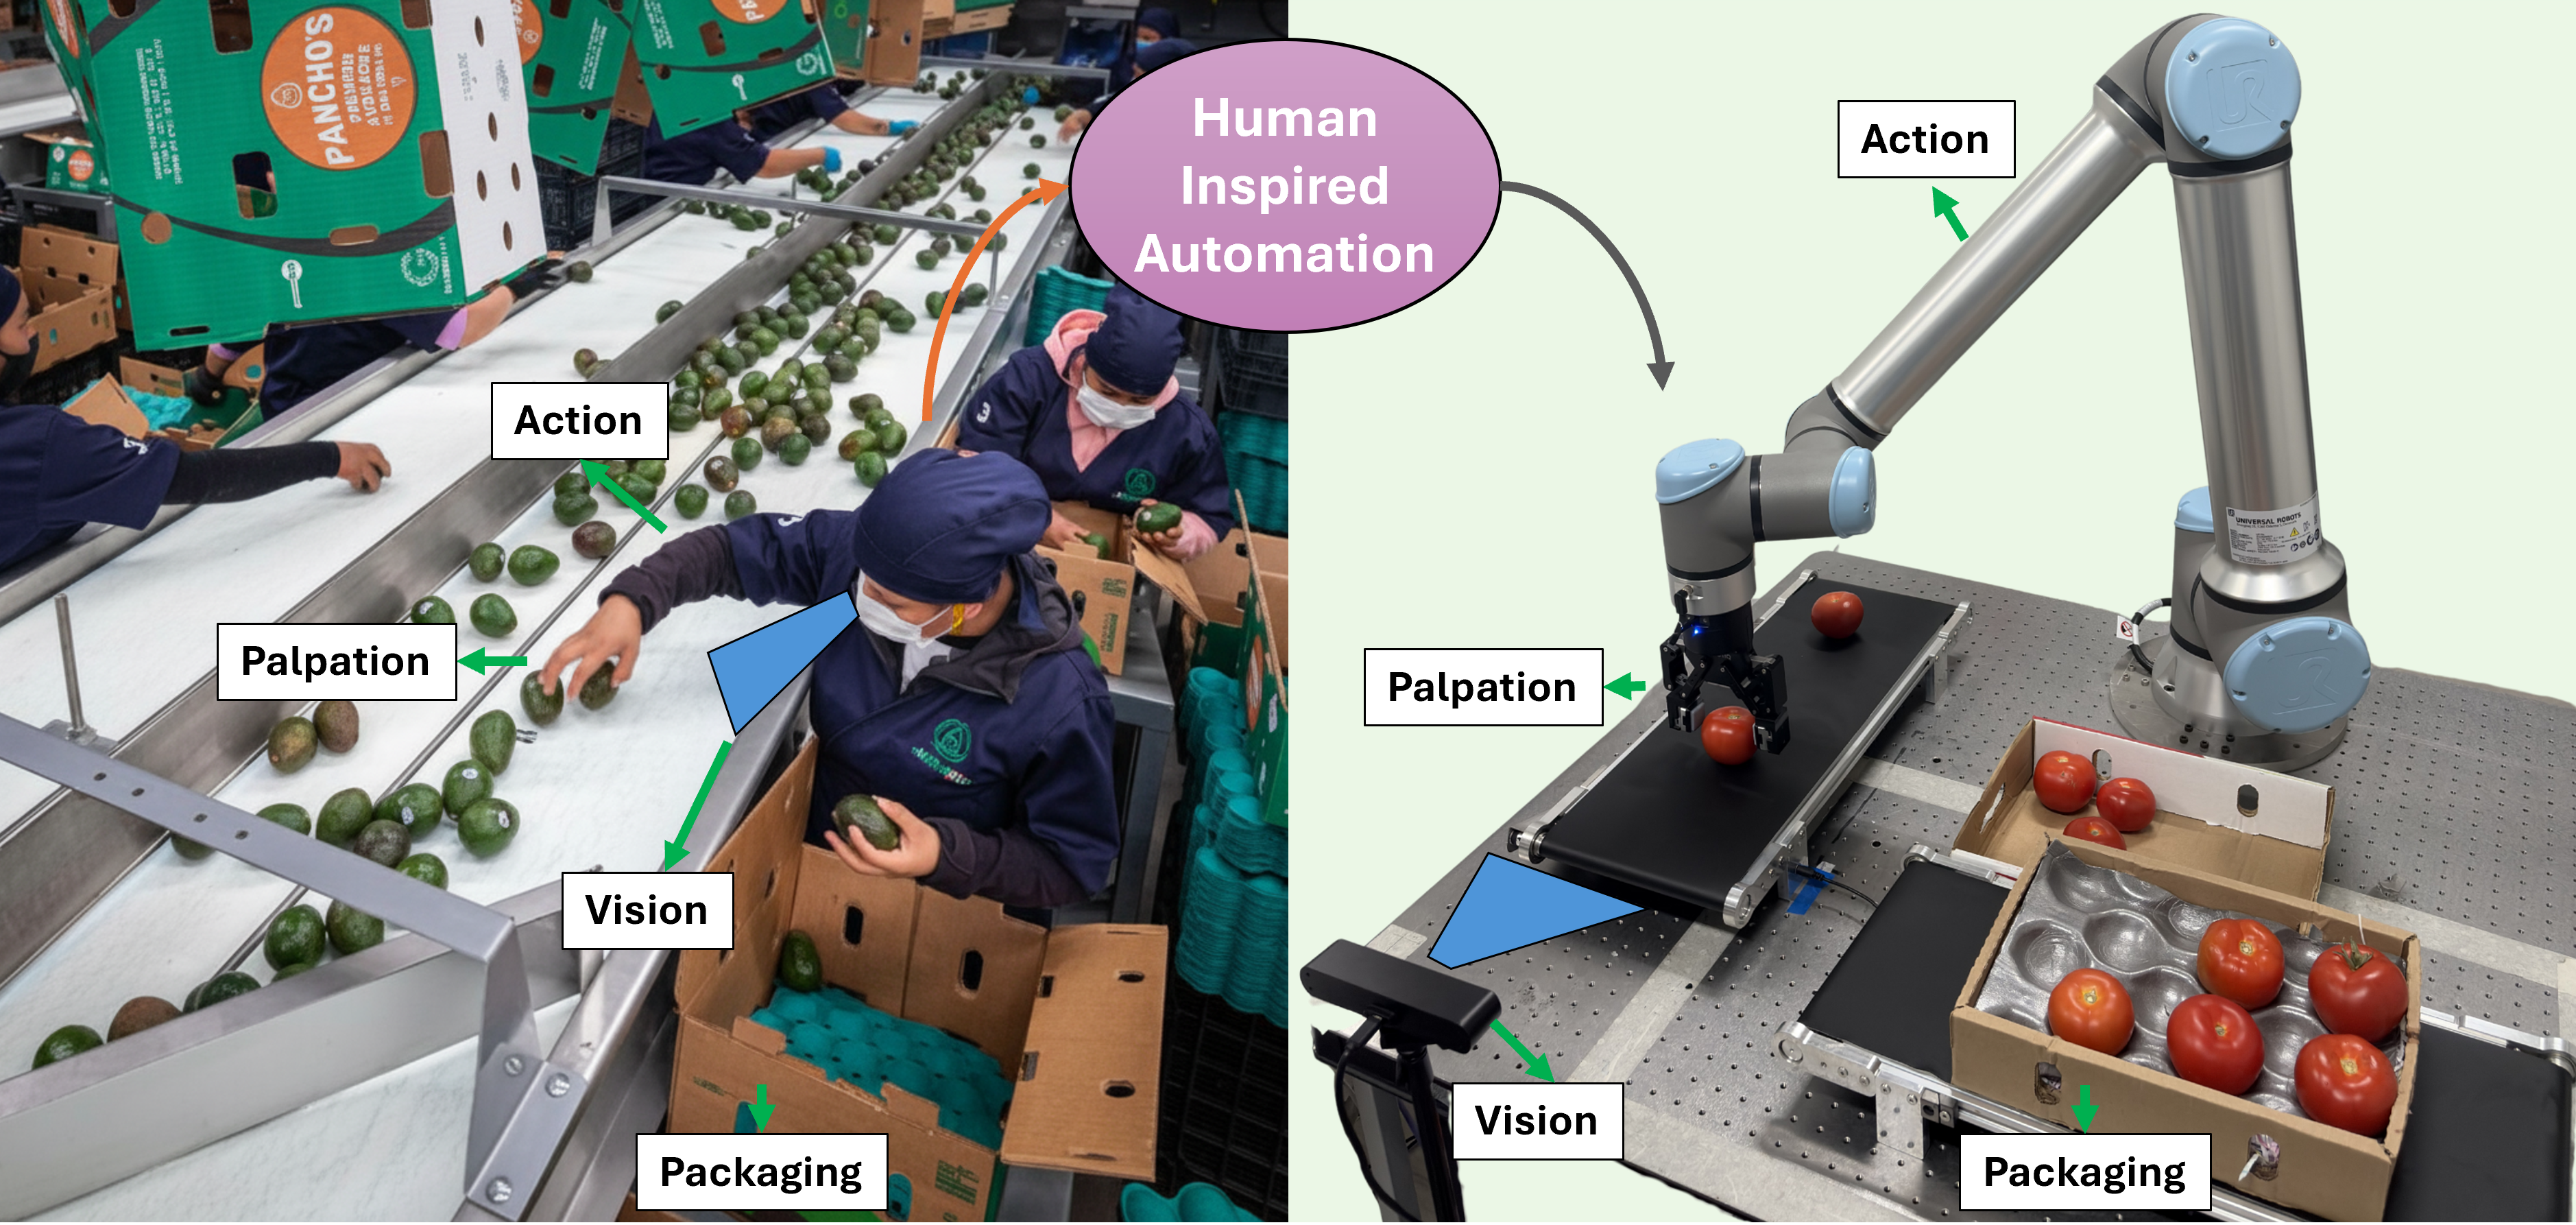
Quality-aware fruit handling is difficult because robots must localize produce and assess firmness during motion. PackRIPE is a human-inspired closed-loop tactile–vision framework combining AI-based perception, reinforcement-learning grasping, and tactile firmness estimation. Using robotic palpation data from 109 UAE tomatoes, it integrates inspection with handling to support packaging or rejection